
Introduction to Measurement Methods for Transmission Errors of Machine Tools
author: Hansheng Automation
2023-05-10
1. Introduction
The transmission error of a machine tool refers to the difference between the actual displacement of its output shaft and the theoretical displacement when the input shaft of the machine tool transmission chain is completely accurate and rigid. The transmission chain required for the composite motion of workpiece surface forming on the machine tool - the "inner contact" transmission chain - must always strictly maintain a motion relationship between the two end effectors that meets the given requirements. The transmission accuracy of a transmission chain refers to the accuracy of its transmission motion, which can be measured by transmission error. Due to the actual transmission chain error of the machine tool, there is an error in the forming motion trajectory of the workpiece surface, which ultimately reflects the shape error of the formed surface on the processed workpiece. Due to the fact that the transmission chain of machine tools mainly consists of gear pairs, worm gear and worm pairs, thread pairs, etc., the transmission chain error mainly comes from the machining accuracy and installation accuracy of these transmission components. From the perspective of kinematics, all factors that cause the instantaneous transmission ratio to deviate from the given transmission requirements are the source of transmission chain error.
The measurement of machine tool transmission error is a prerequisite for effective compensation of transmission error, so precise measurement of machine tool transmission error has always been an important research topic in mechanical transmission technology. The basic measurement method for machine tool transmission error is to install sensors in the relevant parts of the machine tool, use measuring instruments based on mechanical, optical, and electrical principles, and apply error evaluation theory to measure, analyze, and adjust the errors in each link of the machine tool transmission system, in order to identify the reasons for error generation and the patterns of change.
2. Selection of sensors
The correct and reasonable selection and installation of sensors based on the motion properties of the end components of the transmission chain is a necessary condition for accurately measuring the motion accuracy of the transmission chain. According to the working principle, commonly used sensors for measuring machine tool transmission errors can be divided into the following categories:
(1) Grating sensor
The biggest advantage of grating sensors is their simple signal processing method, convenient use, and high measurement accuracy (grating sensors manufactured by well-known foreign manufacturers such as Heidenhain in Germany and Fagor in Spain have an accuracy of up to 1%) μ m/m); The disadvantage is that the grating ruler is expensive and has high requirements for the working environment. The linear expansion coefficient of the glass grating ruler is not consistent with the machine tool, which can easily cause measurement errors.
(2) Laser sensor
Laser sensors (including single frequency and dual frequency lasers) have high measurement accuracy, but the measurement cost is also high. They are sensitive to changes in environmental conditions such as temperature, airflow, vibration, etc. When used in production sites, measures must be taken to ensure the stability and reliability of the measurement.
(3) Magnetic grating sensor
Magnetic grating rulers can be divided into two types: linear (effective measurement length of 3m) and strip (effective measurement length of up to 30m). Their advantages are low manufacturing cost, convenient installation and use, and the same linear expansion coefficient as machine tools; The disadvantage is that the measurement accuracy is lower than that of a grating ruler. Due to the continuous weakening of the magnetic signal strength over time, it is necessary to re record the magnetic field, which brings inconvenience to use.
(4) Inductosyn
The advantages of inductosyn are low manufacturing cost, convenient installation and use, and low requirements for working environment conditions; The disadvantage is that the signal processing method is relatively complex, and the measurement accuracy is limited by the measurement method (the measurement accuracy of traditional measurement methods is about 2-5 μ m)。
According to the different signal output methods, sensors can be divided into two categories: analog and digital. Digital sensors can be divided into several types: incremental, absolute, and signal modulation.
In computer testing systems, the output signal of analog sensors needs to be digitized using analog-to-digital converters (A/D), and the cost of A/D conversion is high in high-resolution situations. In addition, solving the anti-interference problem of small analog signals (such as microvolt level) is also quite difficult.
In digital sensors, absolute encoders can output parallel digital signals without the need for A/D conversion, making it easy to interface with computers. However, with the improvement of measurement accuracy, the cost of absolute encoders is also increasing, even higher than the cost of high-precision A/D conversion, making it difficult to accept in many practical applications. Incremental sensors and signal modulation sensors have lower manufacturing costs and stronger anti-interference capabilities. They can use subdivision technology to significantly improve resolution without changing the encoder line density. Therefore, these two types of sensors are most commonly used in transmission chain accuracy measurement. Common incremental sensors include grating incremental encoders, magnetic grating sensors, capacitive grating encoders, etc; Signal modulation sensors mainly include inductosyn, laser interferometer, seismograph, rotary transformer, etc.
3. Dynamic measurement method for transmission error of machine tools
Basic measurement principle of transmission error: Design θ 1、 θ 2 represents the displacement (angular displacement or linear displacement) of the input and output shafts, and the theoretical transmission ratio between the input and output is i, as shown in θ As a benchmark, the difference between the actual displacement of the output shaft and the theoretical displacement is the transmission chain error δ, Namely δ=θ 2- θ 1/i。 According to the displacement signal θ 1、 θ 2, the measurement methods of transmission error can be divided into two categories: phase comparison measurement method and counting measurement method.
3.1 Measurement method for phase comparison of machine tool transmission error
Output signals of two sensors θ 1、 θ The phase relationship between 2 reflects the transmission error of the transmission chain. When the transmission error TE=0, i.e. the transmission ratio is constant, θ 1、 θ Maintain a constant phase relationship between 2; When the transmission ratio i changes, θ 1、 θ The phase relationship between 2 also changes accordingly. The phase comparison measurement method is achieved by measuring θ 1、 θ The phase relationship between 2 is used to indirectly measure the transmission error TE. With the development of digital and computer technology, the phase comparison measurement method has gone through a development process from analog phase comparison to digital phase comparison and then to computer digital phase comparison.
(1) Analog phase comparison method
The commonly used trigger phase meter adopts the analog phase comparison method. The principle of analog phase comparison: After frequency division, two signals become signals of the same frequency and enter the phase comparator. The time difference between them Δ T depends on θ 1、 θ Phase difference between 2 δ (t)。 After being identified by a bistable trigger, Δ Transform t into an analog quantity corresponding to the duty cycle of the phase comparison rectangular wave Δ u. The change in duty cycle reflects the transmission error of the transmission chain.
The analog phase comparison measurement system has the following problems: ① δ (t) Is a periodic function that takes 2 π as the period and changes according to a certain rule. Let f be the phase change frequency, ω= If 2 π f is the angular frequency, then there is δ (t)= δ ( ω t)。 When comparing two signals, phase measurement is a repeated measurement with a cycle of 1/f, determined by the condition 0 ≤ δ ( ω t) ≤ 2 π indicates that, Δ U and δ (t) Has a linear relationship. because δ ( ω t) Due to periodic changes, it is required to simulate the time constant of the recording header τ The period less than the phase difference of the measured change, i.e τ≤ 1/f, otherwise, when accurate readings have not been obtained within the previous phase change cycle, the subsequent cycle has already begun to repeat, making it impossible to record the changes in phase difference in real time. Therefore, the dynamic measurement performance of the simulation phase comparison method is poor and cannot adapt to the dynamic measurement requirements of real-time analysis and processing The measurement resolution and measurement range are mutually constrained. If the resolution is increased, the range will be reduced. Therefore, a range selection circuit needs to be configured, and the phase difference of the measured signal must be less than 360 ° It is required that the two signals entering the phase comparator have the same frequency, that is, only the same frequency and phase comparison can be performed. Therefore, the frequency divider/frequency multiplier of the two signals must meet the requirements of the transmission ratio change. The circuit structure is complex, the anti-interference ability is poor, and the scope of application is small.
(2) Digital phase comparison method
Digital phase comparison is achieved using logic gates and counters, and phase difference is directly output in digital form. Phase comparison principle: Two signals of the same frequency θ 1、 θ After amplification and shaping, two sets of pulse signals u1 and u2 are obtained, which are respectively controlled to turn the counter on and off through a logic gate circuit. The counting result of the counter is θ 1、 θ Time interval between 2 Δ t. It is different from the phase difference δ (t) Proportional. If the phase comparison signal period is T, then there is δ (t)=2π Δ t/T。e t-value not only depends on the phase difference between the two signals δ (t) And it is also related to the frequency of the two signals. Therefore, in order to obtain high-precision measurement results, it is necessary to ensure that both the phase comparison pulse signal and the clock signal have high accuracy. Within a phase comparison period T, any factor that causes the frequency change of the phase comparison signal will affect the measurement results Although digital phase comparison compensates for some of the shortcomings of analog phase comparison and improves measurement stability and reliability, it can still only be applied to the same frequency phase comparison.
(3) Microcomputer-based subdivision phase comparison method
Since the 1980s, the computerization of testing instruments has become an important development trend in measurement technology. In the measurement of machine tool transmission error, the microcomputer subdivision phase comparison method has begun to be widely used.
The microcomputer subdivision phase comparison method is a computerized application of the digital phase comparison method. Due to the powerful logic, numerical operation, and control functions of computers, it is easy to achieve high-frequency clock subdivision, phase comparison, and output of two signals. Therefore, the production of peripheral circuits is relatively simple. The transmission error is δ (t)=2πNt/N。 During the phase comparison process, high-frequency pulses φ No longer generated by external oscillation circuits, but directly using the internal clock CP of the computer; The counting of pulse CP no longer uses logic gate circuit counters, but uses programmable timing/counters within the computer. The microcomputer subdivision phase comparison measurement method has the following advantages: ① Two phase comparison signals do not need to have the same frequency (i.e. the transmission ratio of the measured transmission chain can be any value), and in the calculation of transmission chain error, the transmission ratio is a constant. ② The phase difference can be any value and is not limited to a phase difference of less than 360 ° The integration of clock subdivision and phase comparison has been achieved, greatly simplifying the hardware interface circuit. Due to the fact that the frequency division of the programmable counter can be controlled by computer software, the sampling frequency can be easily adjusted to adapt to the measurement of transmission chain error at different speeds The system has high subdivision and measurement accuracy, making it easy to form an intelligent and multifunctional measurement system.
3.2 Counting and measuring methods for machine tool transmission errors
Both analog phase comparison and digital phase comparison are in the same frequency phase comparison. In order to obtain the same frequency phase comparison signal, it is necessary to first divide the transmission ratio; To ensure that each error range does not cause 2 π phase flipping, range division is also necessary. Due to the reduction in measurement resolution caused by frequency division, it is necessary to perform frequency doubling before frequency division, which makes the measurement system more complex. In addition, non integer transmission ratios cannot be measured due to the inability to divide frequencies.
The digital counting measurement method uses non same frequency phase comparison, so there is no need to divide the frequency of two pulse signals. The numerical relationship between the output pulses of the two sensors can be directly used to calculate the bed transmission error.
(1) Direct counting measurement method
Principle of direct counting measurement method: Set the number of output signals per revolution of input and output shaft sensors as λ 1、 λ 2. Select the output shaft θ As the reference axis, the sampling interval T is equal to θ The period of a 2-pulse signal or its integer multiple. According to the definition of transmission error, the transmission error at the jth sampling is: δ (j)=[N1(tj)-N2(tj)(i λ 1/ λ 2)]2π/ λ 1。
because θ 1、 θ 2 is a discrete pulse sequence in time, so during the measurement process, the sampling time interval (N2) θ Within 2 pulses θ The count N1 (tj) of 1 pulse varies over time and is usually a non integer. In this way, the decimal part Δ The error caused Δ 2π/ λ 1 was ignored. In addition, the actual transmission system's (i) λ 1/ λ 2) Not necessarily always an integer, i.e. pulse θ The frequency of 1 may not necessarily be θ If N1 theory is treated as an integer multiple of 2, it will cause theoretical errors and limit its application range.
(2) Microcomputer-based subdivision counting measurement method
The measurement steps of the microcomputer subdivision counting measurement method are: ① The previous one θ 2 pulses as the door opening signal, the latter one θ Using 2 pulses as the door closing signal, use a counter to θ Count the number of pulses N0 of 1; ② Using clock pulse CP to pair pulse sequences θ 1. Perform interpolation subdivision to θ Decimal period count value T of 1 pulse signal Δ Count the integer period count value T2 separately; ③ Calculate transmission error: δ (t)=(N0+T Δ/ T2-i λ 1/ λ 2)2π/ λ 1。
The microcomputer subdivision counting measurement method has the following advantages: ① It can effectively reduce measurement errors Δ;② Fully utilize internal computer resources and software control to simplify external hardware circuits; ③ Integrating measurement sampling, data processing, and result analysis has achieved intelligent measurement.
Detailed Analysis of Stamped Bearings
Analysis of PCD and PCBN cutting tools
Related Article

In order to create new products that are constantly emerging on the market, we use different methods to process various materials.
What is Molding Processing? We will introduce some representative molding processing methods

In the context of vehicle electrification and intelligence, human-computer interaction with consumer experience and intelligent control as the core has become an important development theme of intelligent cockpits. The on-board display is at the core of the intelligent cockpit, benefiting from the continuous development of the Internet of Vehicles and smart cars, the on-board display will usher in new development opportunities.
Lighting up new opportunities for automotive electronics - all at the 2025 Guangzhou International Automotive Intelligent Cockpit and Vehicle Display Technology Event

The 2025 Asia International Power Semiconductor, Materials and Equipment Technology Exhibition will focus on "Focusing on Cutting-edge Technology Breakthroughs and Empowering Industrial Innovation and Integration". It will be held on November 20-22, 2025 at Guangzhou Poly World Trade Center Expo!
Focus on the power semiconductor industry - APSME 2025 Asia International Power Semiconductor, Materials and Equipment Technology Exhibition will be held in Guangzhou
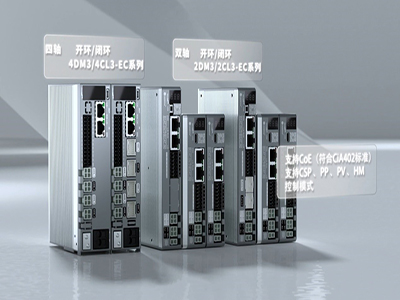
Lexey's multi-axis bus stepper drivers – 2DM3/2CL3-EC (open/closed-loop) dual-axis series and 4DM3/4CL3-EC (open/closed-loop) four-axis series are innovative technologies designed to solve the above problems and help your equipment to achieve efficient upgrades.
"Three provinces" drive: Leisai multi-axis bus stepping, opening a new chapter in the miniaturization and upgrading of precision equipment